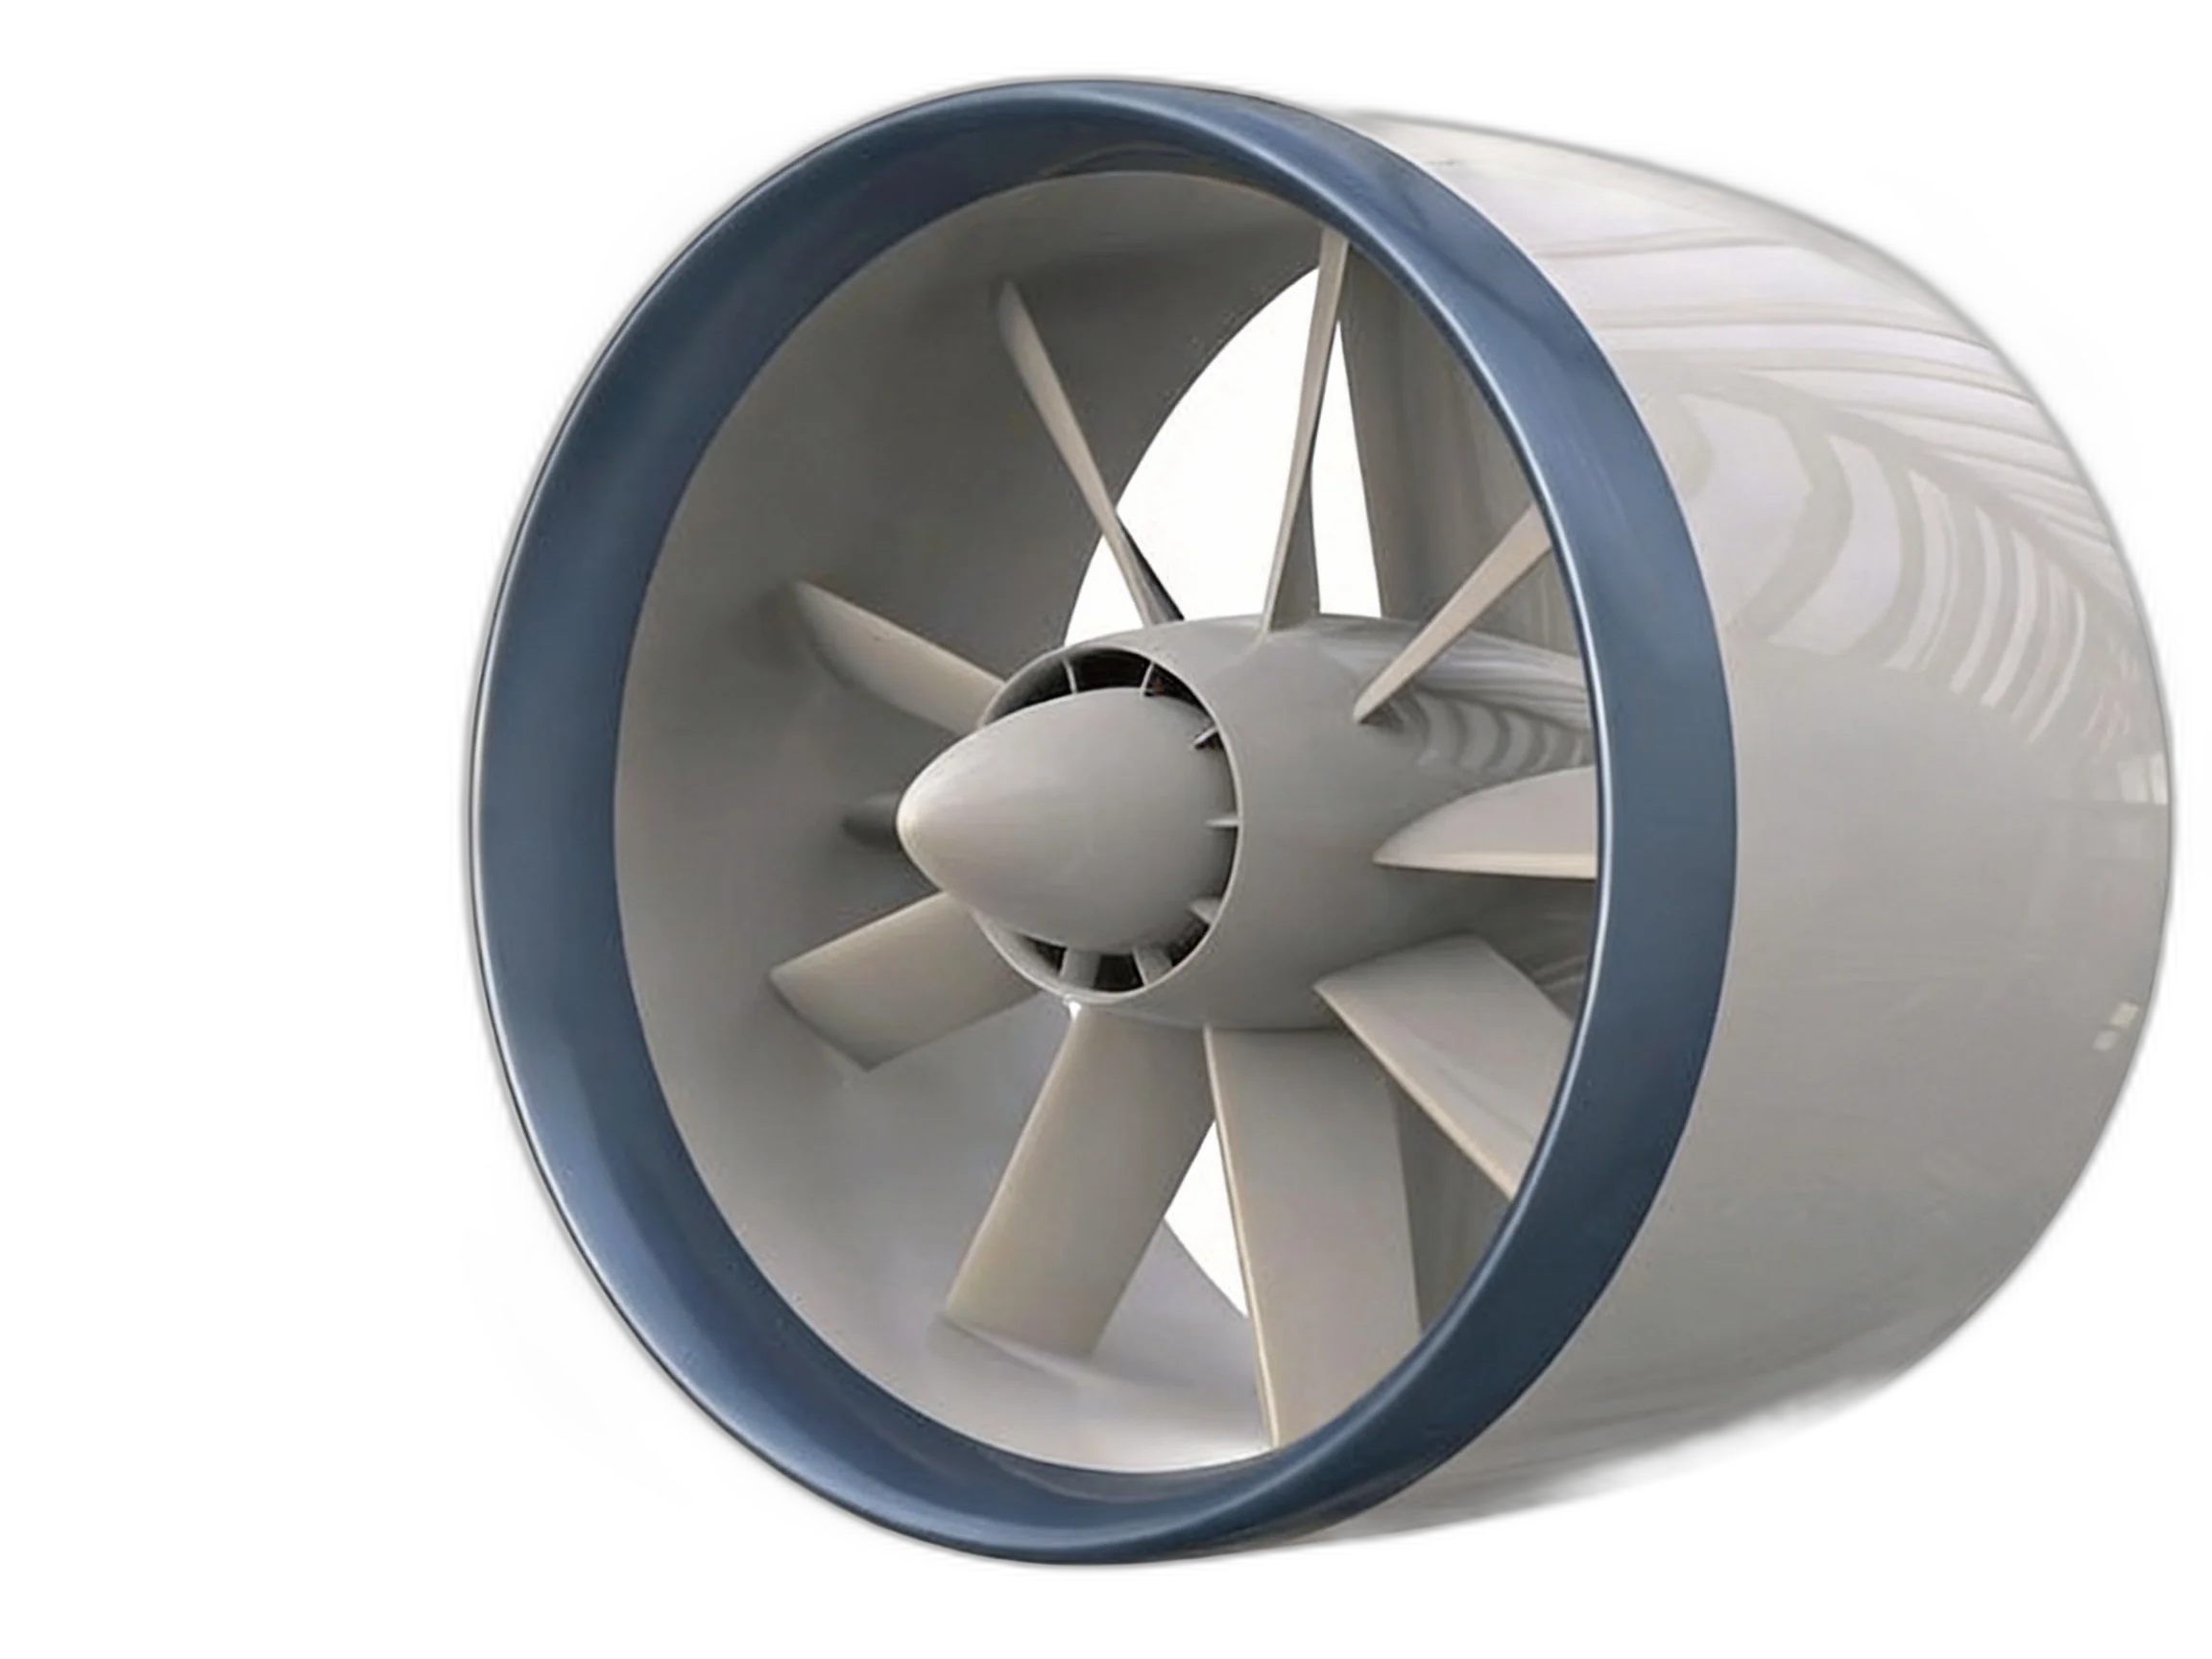
Reference Configuration Specifications
Standard Engineering Envelope & Baseline Performance
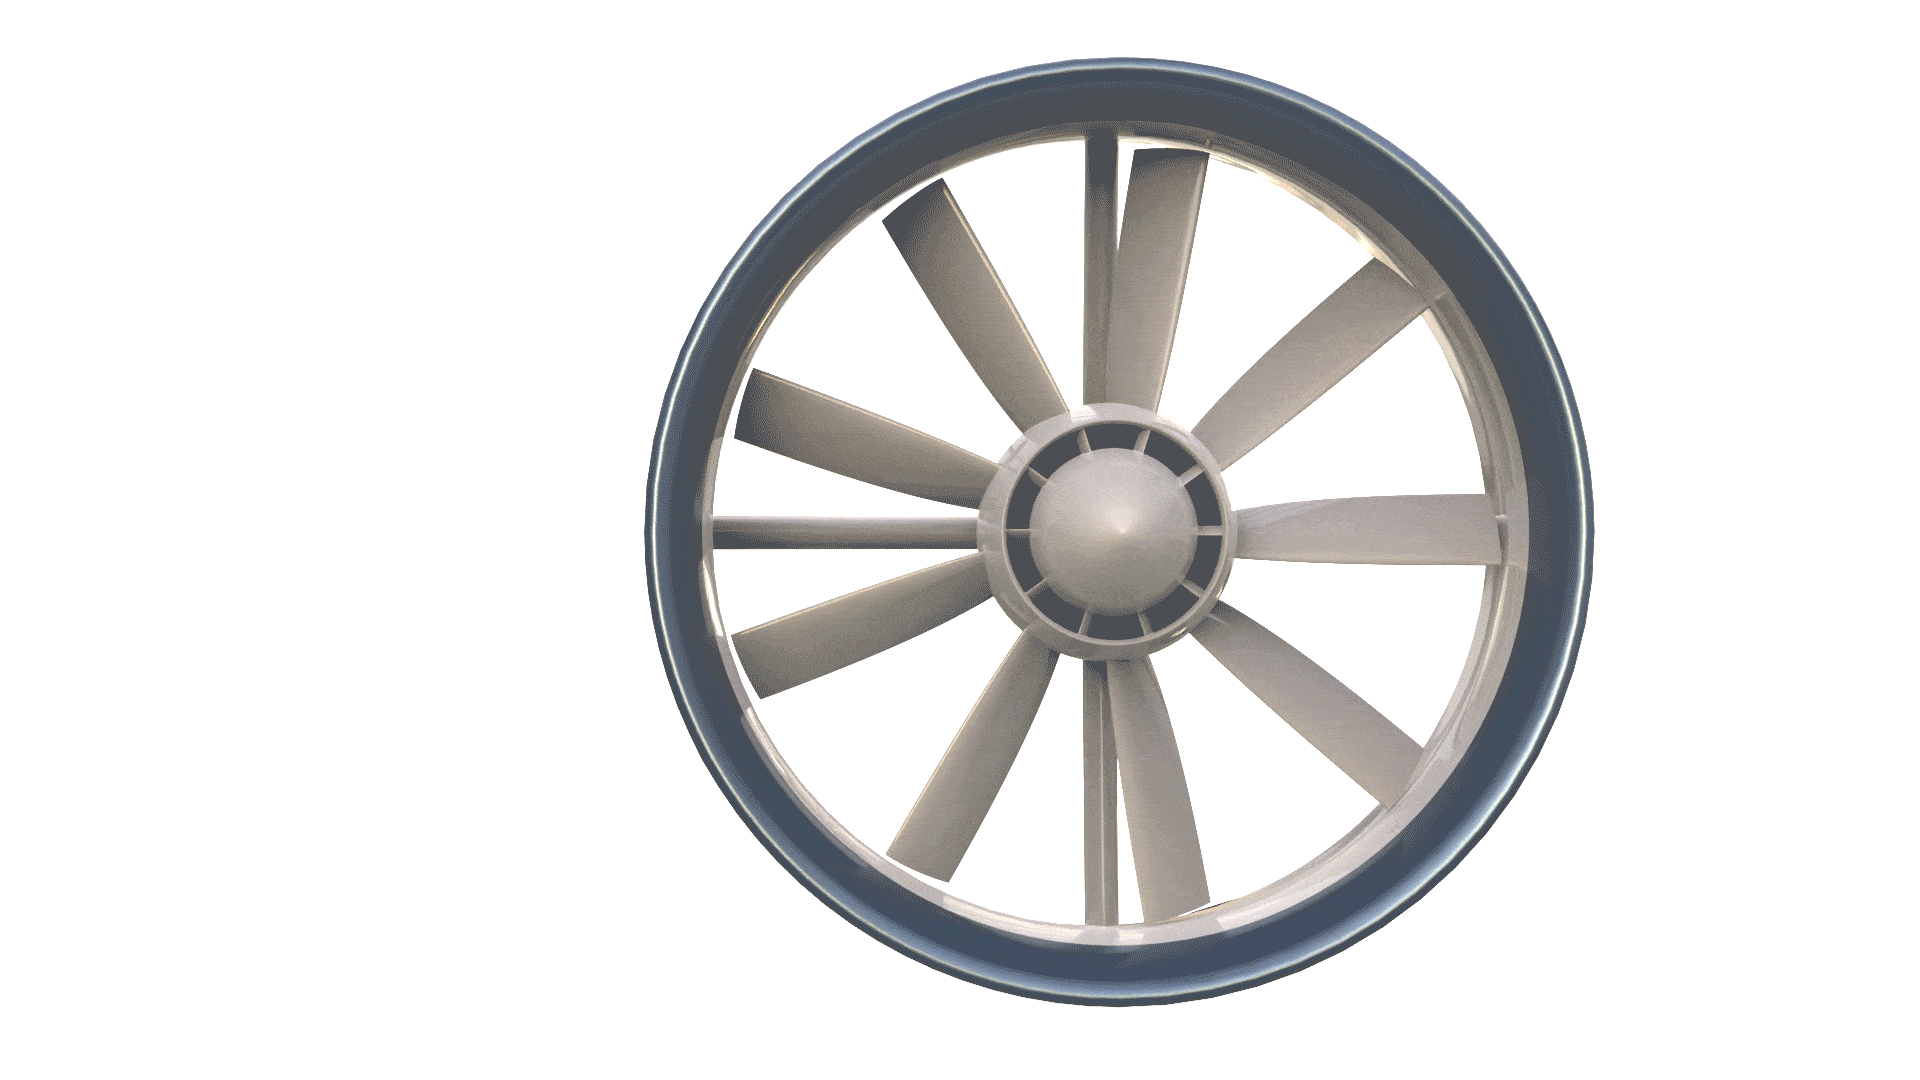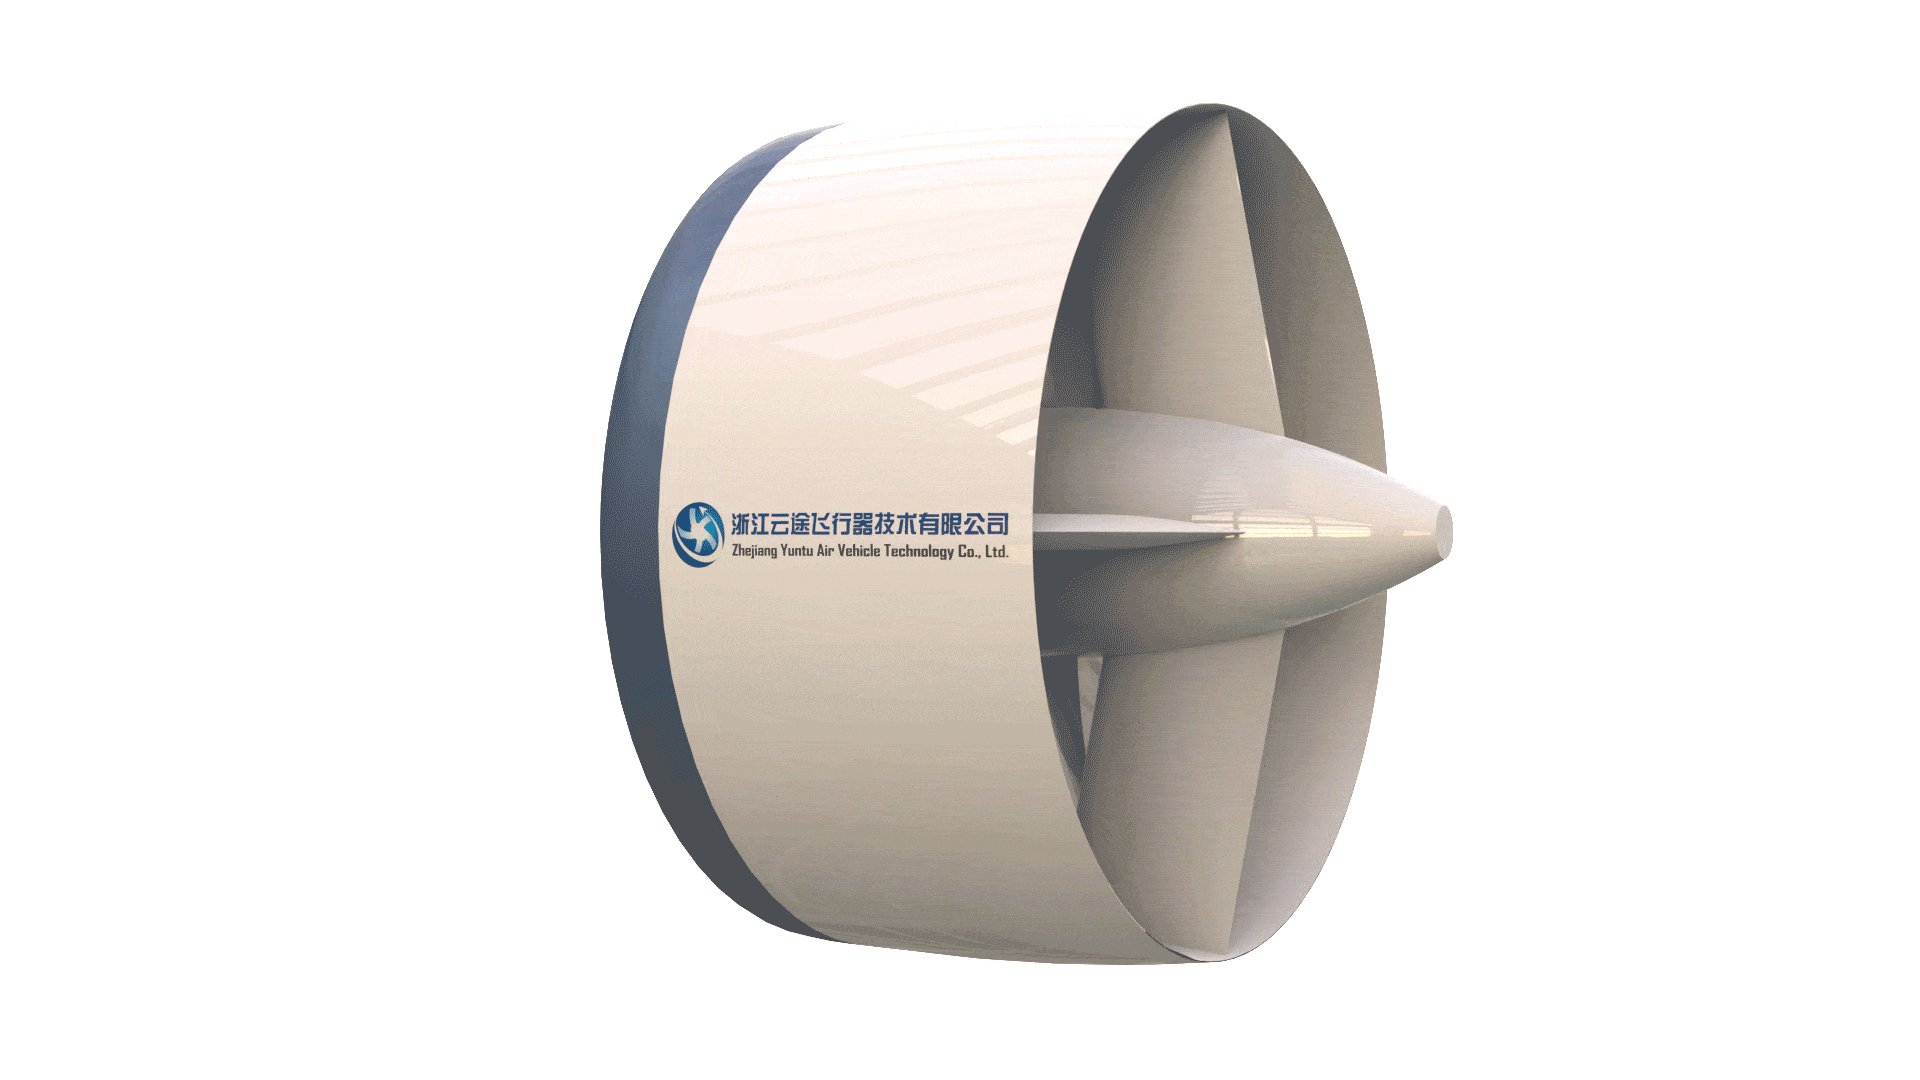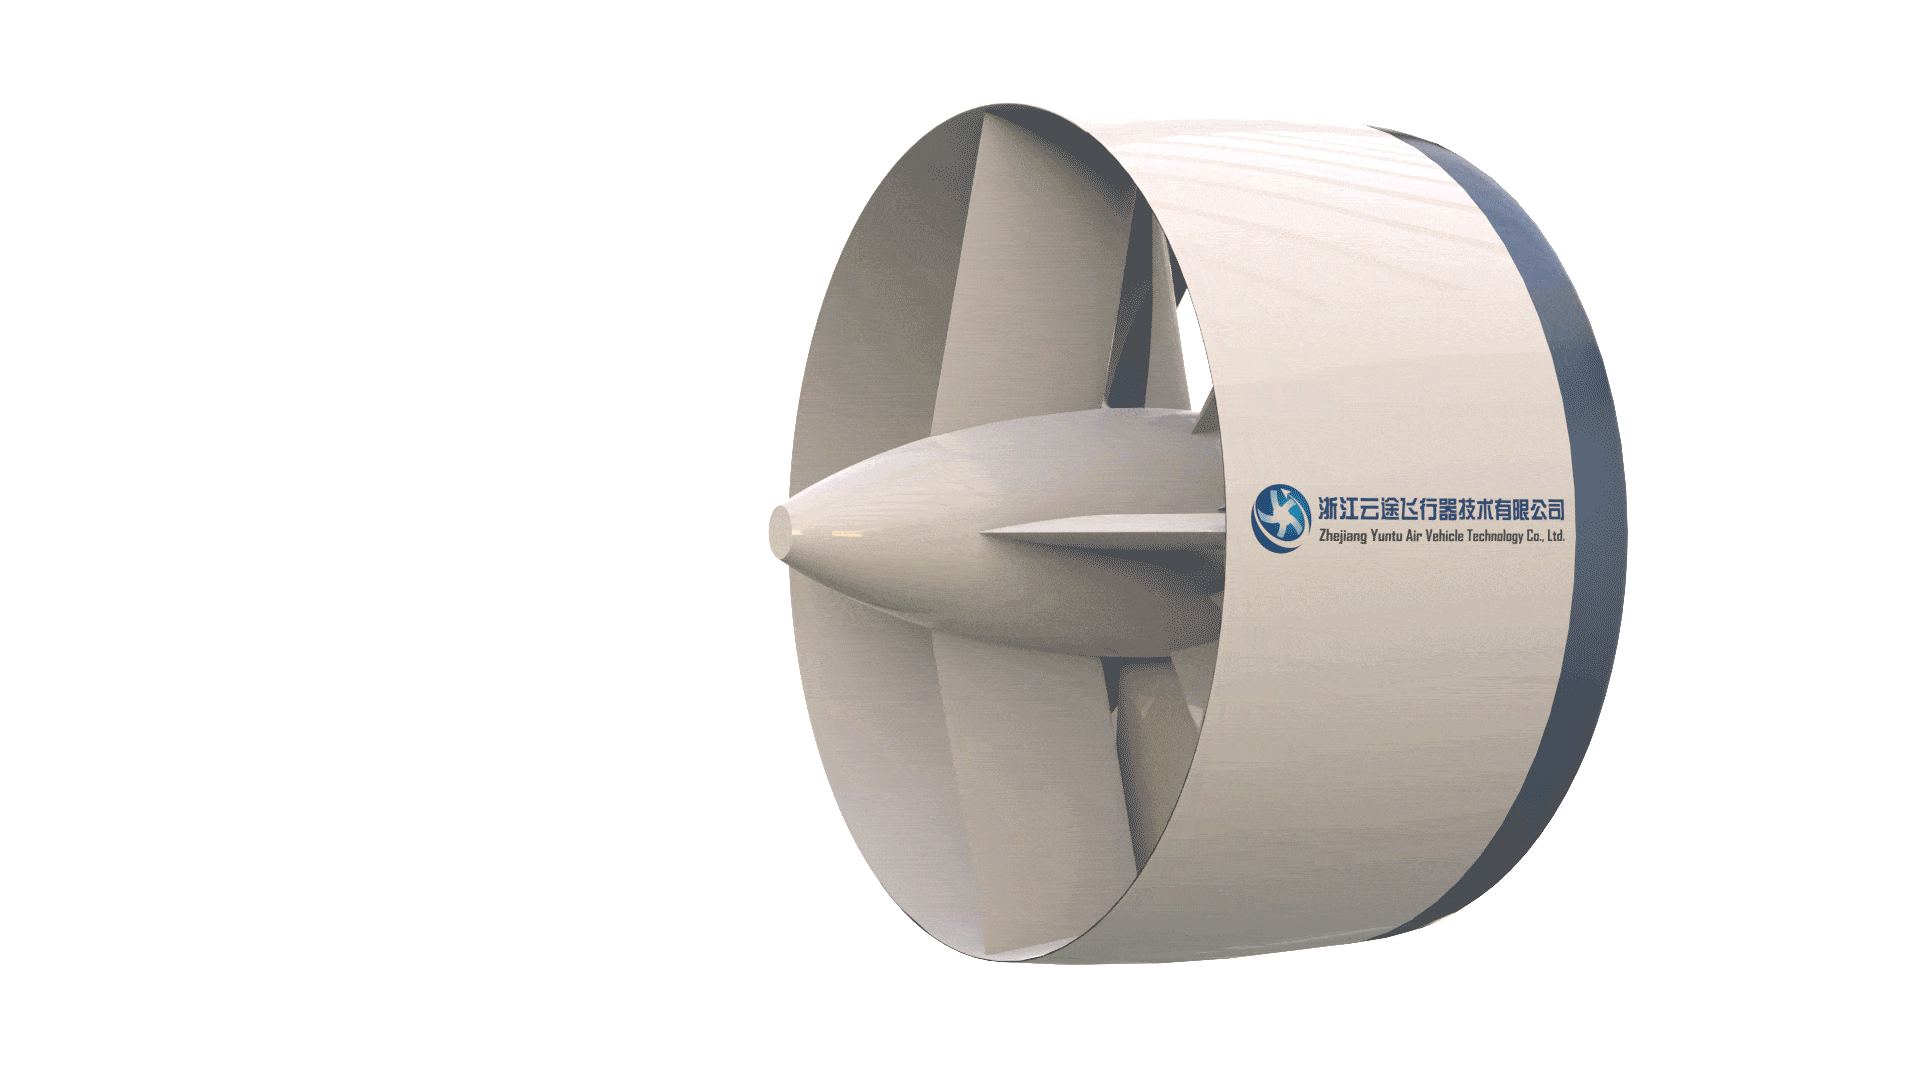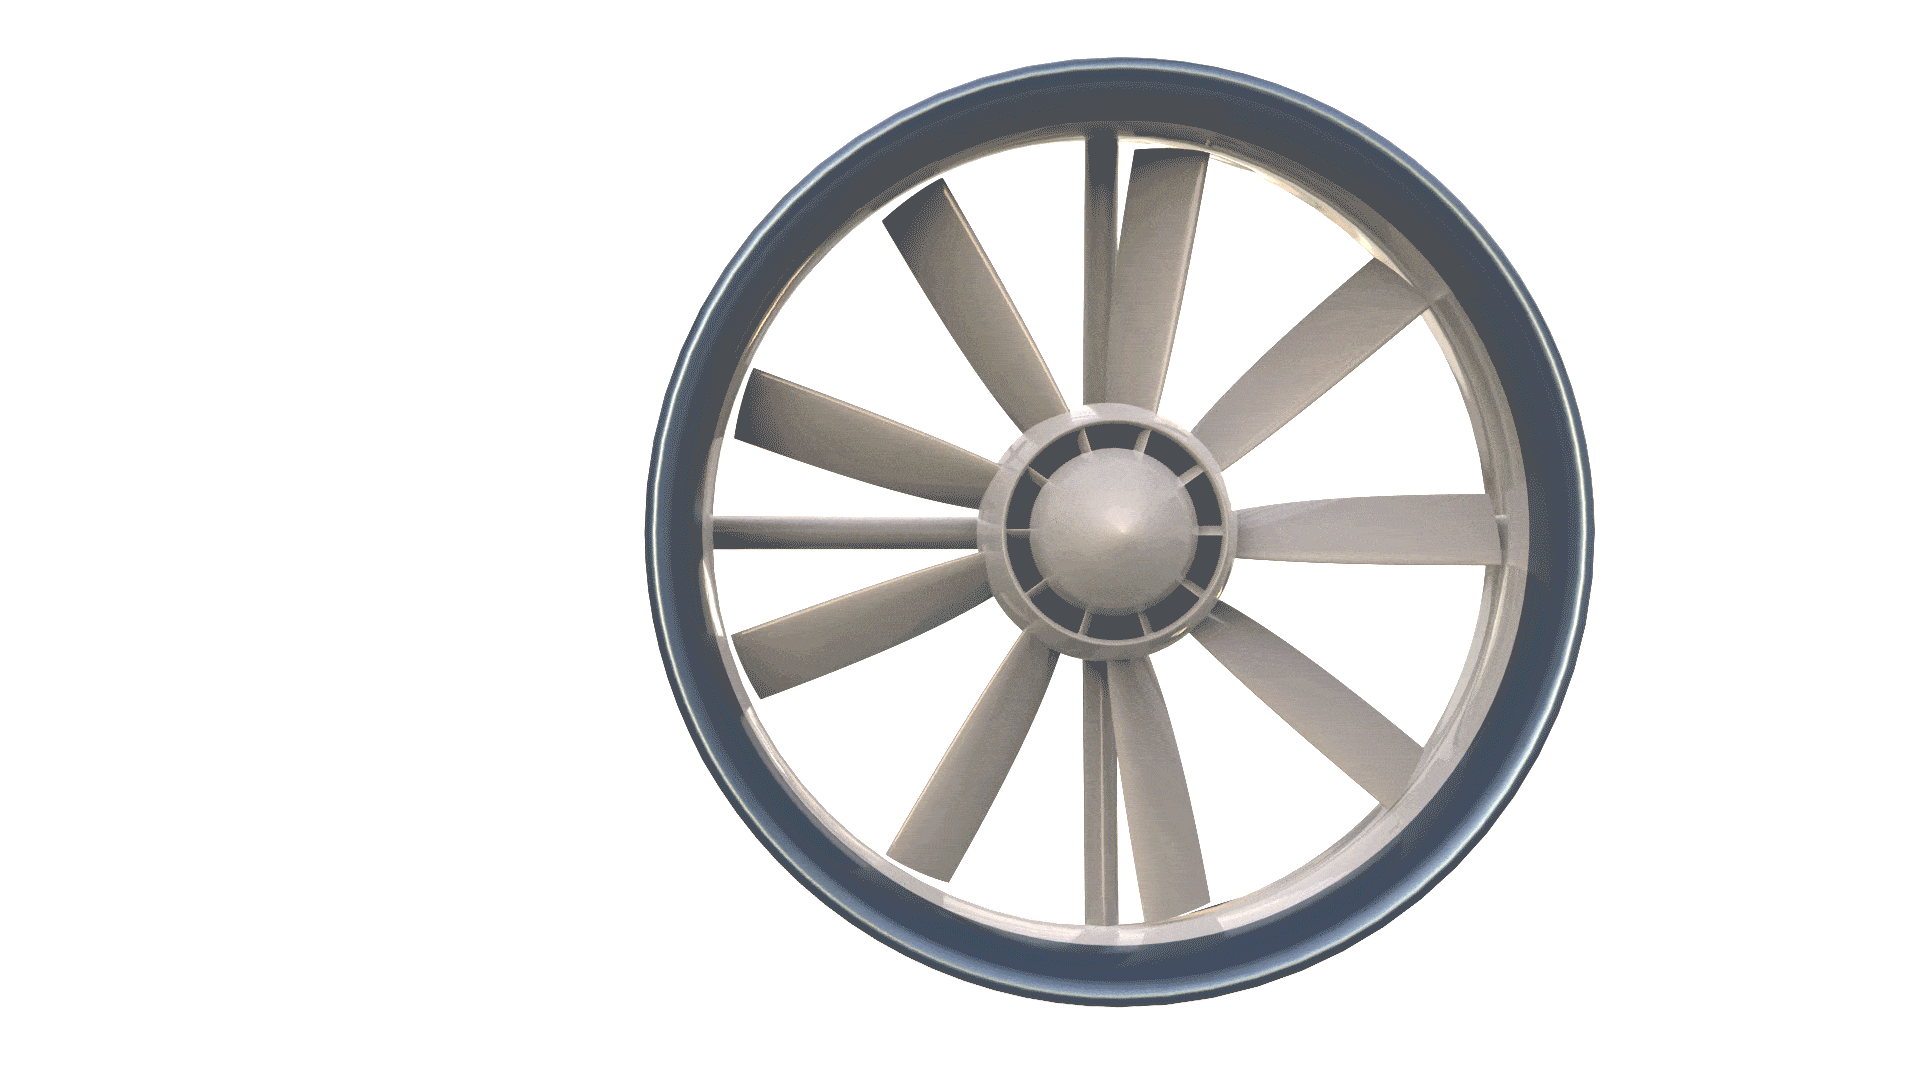 Dynamic 3D Cutaway (9 Blades / 7 Stator Vanes)
Propulsion Engineering Innovations
Optimized for high thrust-to-weight ratio, rapid transient throttle agility, and seamless wing-surface boundary layer blown integration.
Aerodynamic Blown-Wing Nacelle Contour
Contoured duct profile specifically tailored for multi-unit spanwise wing integration, energizing the wing boundary layer and delivering up to a 22% improvement in cruise lift-to-drag ratio.
Sub-200ms Transient Throttle Agility
Ultralow-rotor-inertia design paired with high-bandwidth Field-Oriented Control (FOC). Delivers 0 to 100% full-thrust step changes in under 200 ms for active multi-axis pitch/roll control.
Motor Tail-Cone Air-Cooled SiC Inverter
Aerodynamically integrated into the motor hub tail cone. Utilizes the central core airflow stream for convective cooling, eliminating external coolant lines and saving 4.5 kg of airframe plumbing mass.
Quick-Disconnect Field Replaceable Unit
Incorporates an aerospace quick-clamping radial flange and blind-mate electrical connectors, enabling complete powertrain exchange in under 10 minutes in expeditionary field conditions.
Target Aircraft Configurations
Proven power allocation models for agile cargo drones, high-speed jet-emulation platforms, and distributed lift-plus-cruise aircraft.
600–1,200 kg Long-Endurance Logistics Drone
Dual or quadruple wing-mounted configuration providing high cruise efficiency at 180–240 km/h with extended mission endurance.
High-Speed Jet-Emulation Drone (350+ km/h)
Fuselage-embedded single or twin ducted fan providing high dynamic pressure exhaust and agile high-G acceleration resembling turbojet flight envelopes.
Multi-Unit Agile Lift-Plus-Cruise Aircraft
8 to 12 distributed thrusters along the leading edge generating super-circulation lift during low-speed transition and quiet forward cruise.
Aerospace Engineering Deliverables
Full engineering dataset provided to structural and flight mechanics teams for rapid airframe matching.
High-Speed Wind Tunnel Performance Dataset
Empirical wind tunnel balance polar data across forward velocities from 0 to 100 m/s, documenting duct ram-recovery and aerodynamic drag drag-rise margins.
3D CAD Model & Mechanical Interface Package
Precision mounting ring bolt patterns, rotor polar moment of inertia, and modal resonance vibration frequency charts.
Avionics Control Protocol & Telemetry ICD
Sub-millisecond latency telemetry bus protocol delivering real-time phase currents, rotor angle, PCB temperatures, and vibration alerts.
Multi-Voltage Dynamic Thermal Characteristic Curves
Dynamic acceleration curves covering 400V to 600V DC operating ranges and maximum transient surge current tolerances.
Need Full 3D CAD/STEP Models & Avionics Protocols?
Yuntu provides OEM aircraft design teams with mounting flange CAD, mass moment matrices, and CAN/ARINC ICDs.
Frequently Asked Questions
Related Engineering Deep-Dives
 Technology Deep-Dive
Electric Ducted Fan (EDF) vs Open Propellers: Aerodynamic Efficiency, 53 dB Acoustics & Containment Airworthiness
Explore fluid mechanics of electric ducted fans vs open propellers: tip-vortex loss, lip suction thrust gains, 53 dB acoustics, and FAA Part 23 safety.
 Environmental Test Report
Extreme Environment Qualification: 52°C Heat & Heavy Sandstorm Environmental Chamber Test Report
Official 150-hour qualification test logs in 52°C ambient heat and continuous silica sandstorms. Verified PMSM stator thermal balance and IP67 labyrinth seals.
Compatible Airframe Solutions for 200kgf System
Infrastructure & Inspection Powertrains
Enclosed shroud eliminates cable entanglement during standoff inspection with IP55+ industrial ingress seals.
Cruise Efficiency & Mission Range
Breguet electric range modeling with aft tail-pusher BLI reducing cruise drag by 42% to expand corridor mission radius.
Heavy Lift & Industrial Logistics
Overcoming the open-propeller scaling trap with 20-35% lip suction thrust gain and hot-turnaround cargo safety.
Partners