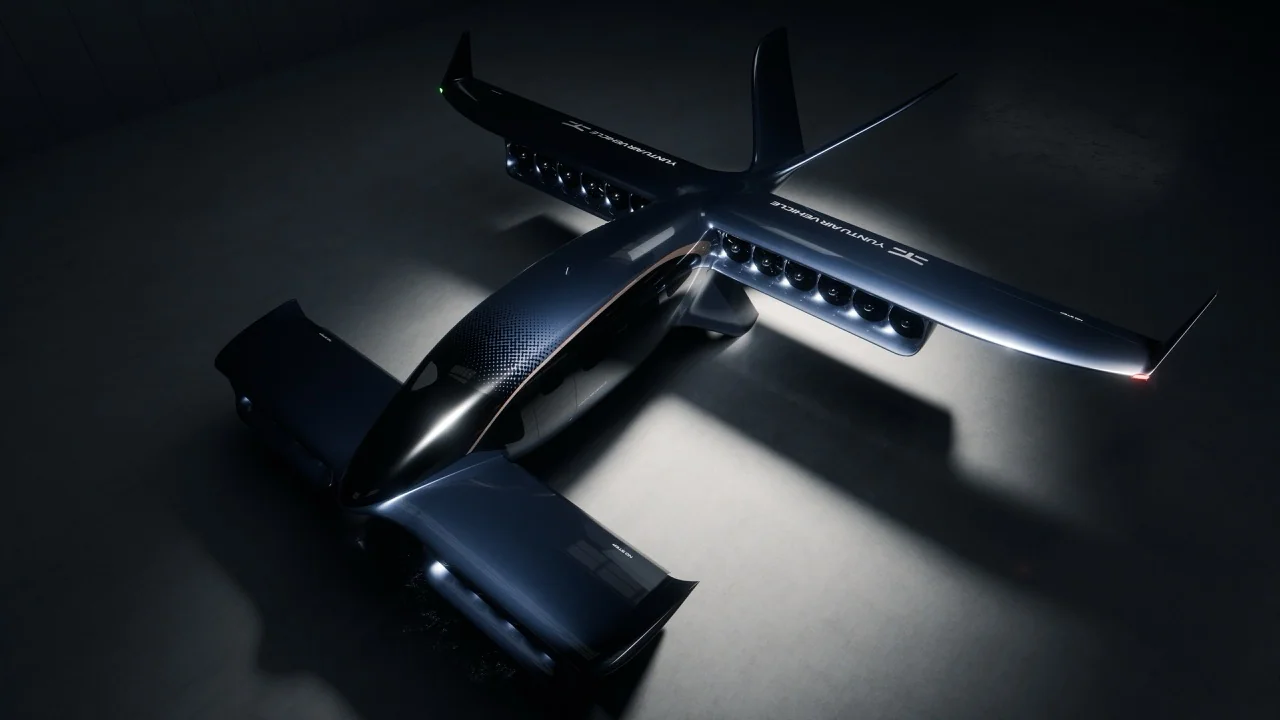
A ducted fan quadcopter uses four electrically driven rotors enclosed by aerodynamic shrouds. Unlike a simple propeller guard, a properly engineered duct is part of the flow path: its inlet lip shapes incoming air, its wall constrains tip leakage, and its downstream geometry influences wake recovery. For industrial UAV teams, the central question is not whether a duct looks safer, but whether the complete propulsion installation improves the mission within acceptable mass, power, thermal, and control margins.
1. What makes a ducted fan quadcopter different?
An open-rotor quadcopter primarily relies on rotor diameter, blade geometry, and rotational speed. An enclosed rotor drone adds a second aerodynamic body around each rotor. The rotor, tip clearance, inlet lip, duct length, stator or support structure, motor, and electronic speed controller must therefore be matched together. A poor inlet or oversized clearance can erase the expected benefit; a well-integrated assembly can provide a predictable compact thrust module with guarded blades.
2. Where enclosed rotors create practical industrial value
- Close-proximity safety: the shroud reduces direct access to the rotating blade and can limit blade contact with walls, cables, vegetation, racks, or inspection targets. The full aircraft still requires an operational safety case; a duct is not a substitute for procedures or redundancy.
- Compact footprint: higher disk loading can place useful thrust inside a smaller external diameter, helping vehicle transport, doorway clearance, and dense propulsion layouts.
- Flow-path control: engineers can shape the inlet lip, tip clearance, stator, and outlet rather than accepting the free-tip flow of an open propeller.
- Acoustic integration: the shroud creates a physical surface for source treatment and directional control, although tonal noise remains dependent on blade count, rotor speed, loading, and installation.
- Modular integration: a qualified propulsion unit can package the motor, rotor, structural mount, guards, sensors, and cooling path as a repeatable subsystem.
3. Missions that are a strong fit
The strongest use cases are not defined by the word “quadcopter” alone. They are missions where the aircraft must work close to assets, people, or confined geometry and where a compact protected rotor is worth the added structure. Typical candidates include bridge and façade inspection, warehouse or tunnel surveys, utility work near cables and towers, emergency observation around obstacles, and heavy sensor platforms that need robust ground handling.
Long-duration open-area mapping may favor large, slow open rotors because low disk loading is efficient in hover. High-speed wing-borne cruise introduces a different trade: nacelle drag, inlet incidence, and whether lift rotors stop or continue operating must be assessed at aircraft level. A ducted configuration is therefore a mission-specific architecture, not a universal upgrade.
4. Limits engineers must calculate before selection
| Decision factor | Ducted rotor | Open rotor | What to verify |
|---|---|---|---|
| Rotor access | Blade perimeter is physically guarded | Blade perimeter is exposed | Guard coverage, impact load path, fragment containment claim |
| External diameter | Can package thrust in a compact module | Often uses a larger disk for low loading | Required thrust, disk loading, vehicle envelope |
| Mass | Adds shroud, supports, and interfaces | Lower structural mass around the rotor | Installed mass, not catalogue motor mass |
| Inlet sensitivity | Performance depends on lip shape and incidence | Less constrained inlet path | Crosswind, yaw, nearby body blockage, test stand correlation |
| Thermal path | Internal flow can support cooling but packaging can trap heat | Motor is more exposed to ambient flow | Continuous winding, bearing, ESC, and cable temperatures |
| Acoustics | Offers surfaces and geometry for acoustic design | Noise radiates from an exposed rotor | Measured spectra at mission operating points |
The most common sizing error is comparing equal outside diameters or equal motor ratings. The useful comparison is mission thrust at the same environmental condition, including installed mass and electrical input power. Tip clearance, inlet separation in crossflow, support-vane blockage, ESC limits, and motor temperature can move the real operating point away from a bench headline.
5. Ducted fan quadcopter sizing checklist
- Define the mission: maximum takeoff mass, payload, hover time, climb rate, wind envelope, altitude, temperature, and proximity hazards.
- Set thrust margin at aircraft level, including controllability after the limiting failure or degraded condition required by the project.
- Compare installed propulsion mass and input power at continuous thrust—not only peak static thrust.
- Validate inlet performance for crosswind, yaw, ground effect, and blockage from arms, fuselage, payload, or nearby surfaces.
- Verify steady-state temperatures for windings, magnets, bearings, inverter, connectors, and cables over the real duty cycle.
- Measure acoustic spectra and vibration at mission operating points; do not extrapolate from rotor speed alone.
- Confirm the structural load path from duct and motor into the airframe, including impact, imbalance, and maintenance access.
- Flight-test control authority across battery voltage, payload, wind, and actuator saturation boundaries.
6. From architecture choice to a testable propulsion specification
Start with the mission envelope, then translate it into continuous and transient thrust, installation volume, bus voltage, cooling, acoustic, and interface requirements. Review the electric ducted fan architecture and available thrust classes for the propulsion building blocks. For vehicle-level redundancy, payload, environmental, and integration decisions, use the commercial and industrial drone propulsion solution as the system-design path.
Ducted Fan Quadcopter FAQ
Is a ducted fan quadcopter always more efficient than an open-rotor quadcopter?
No. Efficiency depends on disk loading, inlet and outlet design, tip clearance, installed mass, rotor operating point, and mission. Large open rotors can be very efficient in hover, while a ducted system may be preferred for protection, compactness, or flow-path integration.
Does a duct make a quadcopter safe to fly near people?
A duct can reduce direct blade-contact risk, but it does not by itself establish operational safety. The aircraft still needs appropriate structural substantiation, failure analysis, flight controls, procedures, and compliance with the rules governing its operation.
Can an existing quadcopter propeller be converted by adding a shroud?
Usually not without redesign and testing. The inlet lip, rotor diameter, tip clearance, motor cooling, supports, outlet flow, control tuning, and airframe load path interact. Treat the conversion as a propulsion-system integration project rather than a bolt-on guard.